PID control: Unterschied zwischen den Versionen
Aus www.wiki.ardumower.de
(→Abstract) |
(→PID controller) |
||
| Zeile 14: | Zeile 14: | ||
D : to reduce over-shooting | D : to reduce over-shooting | ||
I : reduce small error left by P-only | I : reduce small error left by P-only | ||
| + | |||
| + | Examples | ||
| + | |||
| + | [Pid_controller_examples.png] | ||
=Velocity PID= | =Velocity PID= | ||
Version vom 27. Mai 2015, 00:17 Uhr
Abstract
Ardumower uses a digital PID controller for
- heading/course tracking
- perimeter tracking
- motor speed control
- ...
PID controller
Proportional, Integral and Derivative (PID) controller concept:
P : control gain (too high value produces oscillation, too low value too slow control)
D : to reduce over-shooting
I : reduce small error left by P-only
Examples
[Pid_controller_examples.png]
Velocity PID
The standard form is most used for position control. If you derivate the standard form, you obtain the velocity form:
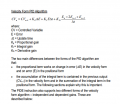
velocity PID

