Hauptseite: Unterschied zwischen den Versionen
Aus www.wiki.ardumower.de
| Zeile 23: | Zeile 23: | ||
|[[Odometry]] | |[[Odometry]] | ||
|[[IMU]] | |[[IMU]] | ||
| − | |||
|[[Rain sensor]] | |[[Rain sensor]] | ||
|- | |- | ||
| Zeile 33: | Zeile 32: | ||
|[[Bluetooth]] | |[[Bluetooth]] | ||
|[[GPS]] | |[[GPS]] | ||
| + | |- | ||
| + | !Other modules | ||
| + | |[[Realtime clock]] | ||
|- | |- | ||
!Computer vision | !Computer vision | ||
Version vom 13. September 2014, 15:11 Uhr
Welcome to the Ardumower Wiki, the wonderful world of DIY robotic mowers...
| Chassis | Ardumower chassis | ||||||
|---|---|---|---|---|---|---|---|
| Arduino, schematics, PCB etc. | Ardumower PCB | ||||||
| Software architecture | Ardumower software design | Ardumower simulator | |||||
| Actuators | Motor driver | Relay | |||||
| Sensors | Perimeter wire | Ultrasonic | Hall sensor | Lawn sensor | Odometry | IMU | Rain sensor |
| Energy | Charging | ||||||
| Wireless | Model R/C | Bluetooth | GPS | ||||
| Other modules | Realtime clock | ||||||
| Computer vision | OpenCV | ||||||
| Arduino code | Arduino crash course | Arduino code techniques |
Help
Overview
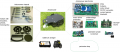
Principle design (v0.9.3)
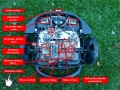
Parts mounted (v0.9.3)


