Hauptseite: Unterschied zwischen den Versionen
Aus www.wiki.ardumower.de
| Zeile 40: | Zeile 40: | ||
|} | |} | ||
| − | + | = Help = | |
* How to edit/add a page: [[Wiki help]] | * How to edit/add a page: [[Wiki help]] | ||
* Use this page to try out any wiki code: [[test]] | * Use this page to try out any wiki code: [[test]] | ||
| − | + | = Overview = | |
<gallery> | <gallery> | ||
File: Ardumower_overview.png|Principle design | File: Ardumower_overview.png|Principle design | ||
File: Ardumower_topics_en.jpg|Parts mounted | File: Ardumower_topics_en.jpg|Parts mounted | ||
</gallery> | </gallery> | ||
| + | |||
| + | = Videos = | ||
| + | #[http://www.youtube.com/watch?v=TRpXDBNEubo&feature=youtu.be Introduction] | ||
| + | #[http://www.ardumower.de/images/l50_arduino1.jpg Ambrogio L50 (1) goes Ardumower] | ||
| + | #[https://www.youtube.com/watch?v=PSE3Z3txa4M Ambrogio L50 (2) goes Ardumower] | ||
| + | #[http://www.youtube.com/watch?v=zglWu2ykDmo Rotenbach SPM08-320 goes Ardumower] | ||
| + | #[http://www.youtube.com/watch?feature=player_embedded&v=RgdiXK1a2Ys Promotion] | ||
Version vom 13. September 2014, 09:20 Uhr
Welcome to the Ardumower Wiki, the wonderful world of DIY robotic mowers...
| Chassis | Ardumower chassis | ||||||
|---|---|---|---|---|---|---|---|
| Arduino, schematics, PCB etc. | Ardumower PCB | ||||||
| Software architecture | Ardumower software design | Ardumower simulator | |||||
| Actuators | Motor driver | Relay | |||||
| Sensors | Perimeter wire | Ultrasonic | Hall sensor | Lawn sensor | Odometry | IMU | Realtime clock |
| Energy | Charging | ||||||
| Wireless | Model R/C | Bluetooth | GPS | ||||
| Computer vision | OpenCV | ||||||
| Arduino code | Arduino code techniques |
Help
Overview
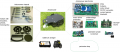
Principle design
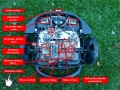
Parts mounted


